Loading...
Searching...
No Matches
elastoplastic::core::StiffnessBase< T > Struct Template Reference
Base class for stiffness. More...
#include <stiffness.hpp>
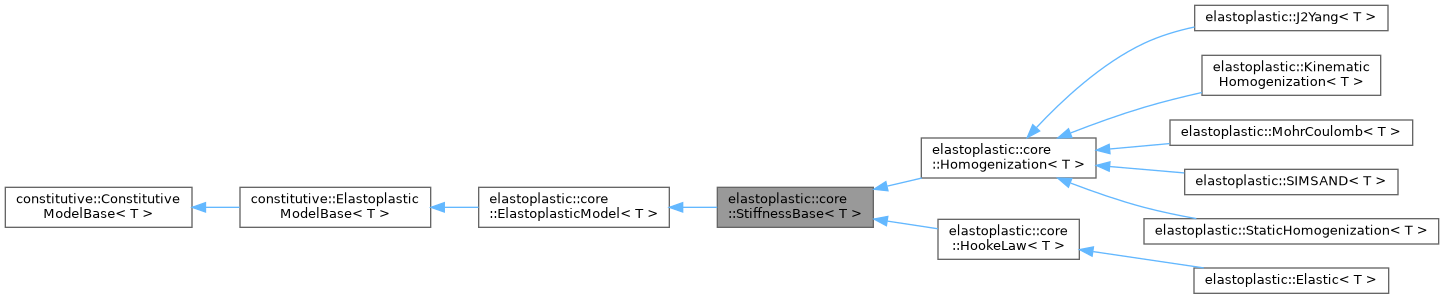
Inheritance diagram for elastoplastic::core::StiffnessBase< T >:
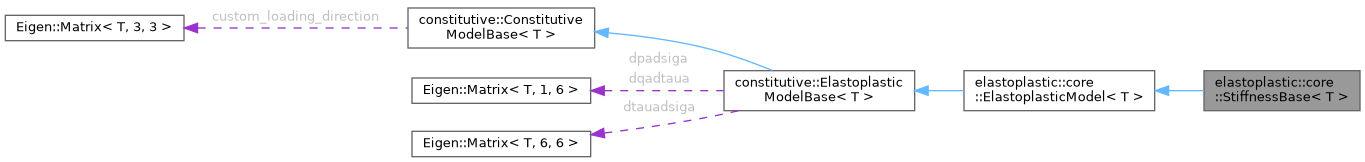
Collaboration diagram for elastoplastic::core::StiffnessBase< T >:
Public Member Functions | |
| std::pair< T, T > | processStiffness () |
| T | E (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| T | nu (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| T | G (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| T | K (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| T | M (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| T | lame (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| Public Member Functions inherited from elastoplastic::core::ElastoplasticModel< T > | |
| ElastoplasticModel (const std::unordered_map< std::string, T > &props) | |
| constructor | |
| ElastoplasticModel ()=default | |
| default constructor | |
| T | phi (const StateVariable< T > &sv0, const StateVariable< T > &sv, bool dilatancy=false) const |
| Lode angle dependent friction angle. | |
| T | phir (const StateVariable< T > &sv0, const StateVariable< T > &sv, bool dilatancy=false) const |
| Lode angle dependent friction angle in radians. | |
| T | CSR (T phir, const StateVariable< T > &sv0, const StateVariable< T > &sv) |
| Critical stress ratio considering fabric anisotropy. | |
| Public Member Functions inherited from constitutive::ElastoplasticModelBase< T > | |
| void | setPlasticMethod (const std::string &method) |
| set the plastic method | |
| Eigen::Matrix< T, 6, 6 > | continuumElastoplasticStiffness (const Eigen::Matrix< T, 6, 6 > &K, const StateVariable< T > &sv0, StateVariable< T > &sv, bool check_elastic_state=true, std::optional< bool > check_positive_definite=std::nullopt, std::optional< bool > check_non_singularity=std::nullopt) override |
| Eigen::Matrix< T, 6, 6 > | symmetricContinuumElastoplasticStiffness (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv, bool check_elastic_state=true, std::optional< bool > check_positive_definite=std::nullopt, std::optional< bool > check_non_singularity=std::nullopt) override |
| Eigen::Matrix< T, 6, 6 > | consistentElastoplasticStiffness (const Eigen::Matrix< T, 6, 6 > &K, const StateVariable< T > &sv0, StateVariable< T > &sv, bool check_elastic_state=true, std::optional< bool > check_positive_definite=std::nullopt, std::optional< bool > check_non_singularity=std::nullopt) override |
| virtual T | yieldFunction (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Yield function for elastoplastic model. | |
| Eigen::Matrix< T, 6, 1 > | dfdsig0 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the stress. | |
| virtual Eigen::Matrix< T, 6, 1 > | dfdsig (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the stress. | |
| Eigen::Matrix< T, 6, 1 > | dfdsig1 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the stress. | |
| Eigen::Matrix< T, 6, 1 > | dfdeps0 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the strain. | |
| virtual Eigen::Matrix< T, 6, 1 > | dfdeps (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the strain. | |
| Eigen::Matrix< T, 6, 1 > | dfdeps1 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the strain. | |
| Eigen::Matrix< T, 6, 1 > | dfdepsp0 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the plastic strain. | |
| virtual Eigen::Matrix< T, 6, 1 > | dfdepsp (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the plastic strain. | |
| Eigen::Matrix< T, 6, 1 > | dfdepsp1 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the yield function with respect to the plastic strain. | |
| Public Member Functions inherited from constitutive::ConstitutiveModelBase< T > | |
| ConstitutiveModelBase ()=default | |
| default constructor | |
| virtual | ~ConstitutiveModelBase ()=default |
| destructor | |
| virtual std::vector< StateVariable< T > > | run () |
| Run the model. | |
| virtual Eigen::Matrix< T, 6, 1 > | increment (const Eigen::Matrix< T, 6, 1 > &dx, Eigen::Matrix< T, 6, 1 > x, const Eigen::Matrix< T, 6, 6 > &S, const Eigen::Matrix< T, 6, 6 > &E, const Eigen::Matrix< T, 6, 6 > &G, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Compute one increment. | |
| void | setElementType (const std::string &element_type) |
| Set ABAQUS element type. | |
| void | setStressStrainComponents (const int ndi, const int nshr) |
| Set number of stress/strain components. | |
| std::tuple< StateVariable< T >, StateVariable< T > > | umat (const T *dload, T *stress, T *statev, T *ddsdde=nullptr, T *sse=nullptr, T *spd=nullptr, T *scd=nullptr) |
| ABAQUS UMAT interface. | |
| void | vumat (const int nBlock, const T *loadInc, const T *stressOld, T *stressNew, const T *stateOld, T *stateNew, const int nStatev) |
| ABAQUS VUMAT interface. | |
| virtual Eigen::Matrix< T, 6, 6 > | stiffness (const StateVariable< T > &sv0, StateVariable< T > &sv)=0 |
| Compute the stiffness matrix. | |
| Eigen::Matrix< T, 6, 6 > | elastoplasticStiffness (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > deps, const StateVariable< T > &sv0, StateVariable< T > &sv, bool check_elastic_state=true, std::optional< bool > check_positive_definite=std::nullopt, std::optional< bool > check_non_singularity=std::nullopt) |
| Compute the elastoplastic stiffness matrix. | |
Protected Member Functions | |
| T | voidRatioFunction (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| T | stressFunction (const StateVariable< T > &sv0, const StateVariable< T > &sv) const |
| virtual Eigen::Matrix< T, 6, 6 > | compliance (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Protected Member Functions inherited from elastoplastic::core::ElastoplasticModel< T > | |
| void | fromAbaqus (StateVariable< T > &sv0, T *statev) override |
| Sync the state variables sv0 from abaqus statev. | |
| void | toAbaqus (const StateVariable< T > &sv0, StateVariable< T > &sv, T *statev) override |
| Sync the state variables sv to abaqus statev. | |
| StateVariable< T > | createStateVariable () override |
| Create a new state variable object. | |
| void | initialize (StateVariable< T > &sv) override |
| Initialize the state variables. | |
| void | preIncrement (const StateVariable< T > &sv0, StateVariable< T > &sv) override |
| Pre-processing before the increment. | |
| void | postIncrement (const StateVariable< T > &sv0, StateVariable< T > &sv) override |
| Post-processing after the increment. | |
| void | postProcess (StateVariable< T > &sv) override |
| Post-process the state variables. | |
| bool | converged (const StateVariable< T > &sv0, StateVariable< T > &sv) override |
| Whether the current stress state can be accepted as converged, used for elastoplastic substepping. | |
| virtual T | stateParameter (const StateVariable< T > &sv0, StateVariable< T > &sv, std::optional< T > e=std::nullopt, std::optional< T > ec=std::nullopt) const |
| State parameter. | |
| virtual T | densityEffectOnStrength (const StateVariable< T > &sv0, StateVariable< T > &sv, std::optional< T > e=std::nullopt, std::optional< T > ec=std::nullopt) const |
| Density effect on strength. | |
| virtual T | densityEffectOnDilatancy (const StateVariable< T > &sv0, StateVariable< T > &sv, std::optional< T > e=std::nullopt, std::optional< T > ec=std::nullopt) const |
| Density effect on dilatancy. | |
| virtual T | Mp (const StateVariable< T > &sv0, StateVariable< T > &sv, std::optional< T > e=std::nullopt, std::optional< T > ec=std::nullopt) |
| T | dMpde (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| T | dMpdec (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| virtual T | Mpt (const StateVariable< T > &sv0, StateVariable< T > &sv, std::optional< T > e=std::nullopt, std::optional< T > ec=std::nullopt) |
| T | dMptde (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| T | dMptdec (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| virtual Eigen::Matrix< T, 6, 1 > | dCSRdsig (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the critical stress ratio with respect to the stress. | |
| virtual Eigen::Matrix< T, 6, 1 > | dMpdsig (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the peak stress ratio with respect to the stress. | |
| Protected Member Functions inherited from constitutive::ElastoplasticModelBase< T > | |
| bool | isExplicit () const |
| check if the plastic method is explicit | |
| bool | isCPA () const |
| check if the plastic method is CPA | |
| bool | isCPPM () const |
| check if the plastic method is CPPM | |
| bool | isRungeKutta () const |
| check if the plastic method is RungeKutta | |
| void | stressStrainIntegrate (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &dsig, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) override |
| Stress-strain integration. | |
| void | returnMapping (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &dsig, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| return mapping algorithm to solve plastic problem (plastic strain and stress) | |
| T | elasticTrial (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Perform the elastic trial. | |
| void | revertElasticTrial (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Revert the elastic trial. | |
| virtual void | beginConstantStressStateScope (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Begin the scope of a constant stress state which can be used to cache intermediate variables for the plastic correction, such as derivatives of the yield and plastic potential functions, and hardening law. | |
| void | beginConstantStressStateScope1 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Begin the scope of a constant stress state which can be used to cache intermediate variables for the plastic correction, such as derivatives of the yield and plastic potential functions, and hardening law. | |
| virtual void | endConstantStressStateScope (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| End the scope of a constant stress state. | |
| void | endConstantStressStateScope1 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| End the scope of a constant stress state. | |
| void | ExplicitCPA (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Explicit/CPA methods for elastoplastic model. | |
| void | CPPM (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| CPPM method for elastoplastic model. | |
| std::tuple< bool, T > | integrateToYieldSurface (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Integrate stress state to the yield surface elastically, solve f(sig0 + alpha * K * deps) = 0. | |
| std::tuple< Eigen::Matrix< T, 6, 6 >, Eigen::Matrix< T, 6, 1 >, Eigen::Matrix< T, 6, 1 >, Eigen::Matrix< T, Eigen::Dynamic, 1 >, Eigen::Matrix< T, Eigen::Dynamic, 6 > > | RKn (int n, const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv, const bool revert=false) |
| Perform a Runge-Kutta increment. | |
| void | RungeKutta (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv, std::optional< int > order=std::nullopt) |
| Runge-Kutta method for elastoplastic model. | |
| virtual T | CSL (const StateVariable< T > &sv0, StateVariable< T > &sv) const |
| calculate the critical state line | |
| T | yieldFunction1 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Yield function for elastoplastic model. | |
| Eigen::Matrix< T, 6, 6 > | dsigadsig (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the modified stress with respect to the stress. | |
| virtual T | potentialFunction (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Potential function for elastoplastic model. | |
| Eigen::Matrix< T, 6, 1 > | dgdsig0 (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the potential function with respect to the stress. | |
| virtual Eigen::Matrix< T, 6, 1 > | dgdsig (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Derivative of the potential function with respect to the stress. | |
| Eigen::Matrix< T, 6, 1 > | dgdsig1 (const Eigen::Matrix< T, 6, 1 > &dfdsig, const StateVariable< T > &sv0, StateVariable< T > &sv, std::optional< bool > associated=std::nullopt) |
| Derivative of the potential function with respect to the stress. | |
| Eigen::Matrix< T, 6, 6 > | d2gdsig20 (const Eigen::Matrix< T, 6, 1 > &dfdsig, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Second-order derivative of the potential function with respect to the stress. | |
| virtual Eigen::Matrix< T, 6, 6 > | d2gdsig2 (const Eigen::Matrix< T, 6, 1 > &dfdsig, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Second-order derivative of the potential function with respect to the stress. | |
| Eigen::Matrix< T, 6, 6 > | d2gdsig21 (const Eigen::Matrix< T, 6, 1 > &dfdsig, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Second-order derivative of the potential function with respect to the stress. | |
| virtual T | plasticModulus (const Eigen::Matrix< T, 6, 1 > &dgdsig, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Plastic modulus for elastoplastic model, including dgdsig. | |
| T | plasticModulus1 (const Eigen::Matrix< T, 6, 1 > &dgdsig, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Plastic modulus for elastoplastic model, including dgdsig. | |
| virtual void | updateHardeningVariables (const T ddlambda, const Eigen::Matrix< T, 6, 1 > &ddepsp, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Update the hardening variables. | |
| virtual void | yieldFunctionCorrection (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &deps, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Yield surface correction to keep the force state on the yield surface. | |
| Eigen::Matrix< T, 3, 3 > | orthogonalDirection (const Eigen::Matrix< T, 3, 3 > &F, const Eigen::Matrix< T, 3, 3 > &n) const |
| Orthogonal direction. | |
| Eigen::Matrix< T, 3, 3 > | nonCoaxialDirection (const Eigen::Matrix< T, 3, 3 > &F, const Eigen::Matrix< T, 3, 3 > &n, const Eigen::Matrix< T, 3, 3 > &m) const |
| Non-coaxial direction. | |
| void | interpolateFabricTensor (const StateVariable< T > &sv0, StateVariable< T > &sv, const bool clear_caches=true, std::optional< std::string > combined_stress_tensor_type=std::nullopt) |
| Interpolate fabric tensor towards critical state. | |
| Protected Member Functions inherited from constitutive::ConstitutiveModelBase< T > | |
| bool | checkStiffnessMatrix (const Eigen::Matrix< T, 6, 6 > &K, std::optional< bool > check_positive_definite=std::nullopt, std::optional< bool > check_non_singularity=std::nullopt) |
| Check whether the stiffness matrix is valid. | |
| T | updateVoidRatio (T e0, StateVariable< T > &sv) |
| Update the void ratio after the isotropic loading to the void ratio before the isotropic loading. | |
| virtual void | postInitialize (StateVariable< T > &sv) |
| Post-initialize the state variables. | |
| void | saveElasticStiffnessMatrix (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Save elastic stiffness matrix. | |
| virtual void | preStressStrainIntegrate (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Pre-processing before the stress-strain integration. | |
| virtual void | postStressStrainIntegrate (const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Post-processing after the stress-strain integration. | |
| std::tuple< Eigen::Matrix< T, 6, 1 >, Eigen::Matrix< T, 6, 1 > > | linearize (const Eigen::Matrix< T, 6, 6 > &K, const Eigen::Matrix< T, 6, 1 > &dx, const Eigen::Matrix< T, 6, 6 > &S, const Eigen::Matrix< T, 6, 6 > &E, const Eigen::Matrix< T, 6, 6 > &G, const StateVariable< T > &sv0, StateVariable< T > &sv) |
| Linearize the stress and strain increment. | |
| void | resetCustomStateVariables (StateVariable< T > &sv0, StateVariable< T > &sv) |
| Reset the custom state variables to zeros existing in the current state variables but not in the initial state variables. | |
| Eigen::Matrix< T, 3, 3 > | loadingDirection (const StateVariable< T > &sv0, StateVariable< T > &sv) const |
| loading direction | |
Additional Inherited Members | |
| Public Attributes inherited from elastoplastic::core::ElastoplasticModel< T > | |
| std::shared_ptr< FabricTensor< T > > | fabric = std::make_shared<FabricTensor<T>>("chang1990-ext", "li2012") |
| std::shared_ptr< ElastoplasticMaterial< T > > | material |
| Public Attributes inherited from constitutive::ElastoplasticModelBase< T > | |
| std::string | plasticMethod = "CPA" |
| Plastic method. | |
| Public Attributes inherited from constitutive::ConstitutiveModelBase< T > | |
| std::string | name = "Undefined" |
| name of the model | |
| std::shared_ptr< Load< T > > | load = std::make_shared<Load<T>>() |
| load | |
| std::shared_ptr< Options< T > > | options = std::make_shared<Options<T>>() |
| options for the constitutive model | |
| std::shared_ptr< DebugVariable< T > > | debugVariable = std::make_shared<DebugVariable<T>>() |
| debug variable | |
| std::vector< StateVariable< T > > | stateVars = {} |
| state variables of the current run | |
| Eigen::Matrix< T, 3, 3 > | custom_loading_direction = Eigen::Matrix<T, 3, 3>::Zero() |
| custom loading direction | |
| bool | abaqus_initialize = false |
| Options for abaqus UMAT/VUMAT interfaces. | |
| bool | abaqus_normalize_ddsdde = true |
| whether to normalize stiffness matrix | |
| bool | abaqus_strain_control = true |
| the load is controlled by strain (true) or stress (false) | |
| bool | abaqus_disable_unused_components = false |
| whether to disable unused components in the flow rule | |
| int | abaqus_ndi = 3 |
| number of direct stress/strain components | |
| int | abaqus_nshr = 3 |
| number of shear stress/strain components | |
| std::string | abaqus_stiffness_type = "elastic" |
| T | abaqus_elastoplastic_stiffness_strain_increment_multiplier = 1.0 |
| multiplier for strain increment when computing elastoplastic stiffness matrix | |
| bool | abaqus_check_stiffness_matrix_positive_definite = true |
| whether to check the positive definiteness of the stiffness matrix | |
| bool | abaqus_check_stiffness_matrix_non_singularity = true |
| whether to check the non-singularity of the stiffness matrix | |
| int | _phase = 0 |
| index of the phase | |
| int | _step = 0 |
| current step | |
| int | _mixedLoad = 0 |
| number of mixed load steps | |
| Protected Attributes inherited from constitutive::ElastoplasticModelBase< T > | |
| std::string | state = "none" |
| bool | cached_ = false |
| whether the state variables have been cached | |
| Eigen::Matrix< T, 1, 6 > | dpadsiga = {-1.0 / 3.0, -1.0 / 3.0, -1.0 / 3.0, 0.0, 0.0, 0.0} |
| Eigen::Matrix< T, 1, 6 > | dqadtaua = Eigen::Matrix<T, 1, 6>::Zero() |
| Eigen::Matrix< T, 6, 6 > | dtauadsiga |
| Protected Attributes inherited from constitutive::ConstitutiveModelBase< T > | |
| T | _e0 = 0.0 |
| original void ratio | |
Detailed Description
template<typename T>
struct elastoplastic::core::StiffnessBase< T >
struct elastoplastic::core::StiffnessBase< T >
Base class for stiffness.
Member Function Documentation
◆ compliance()
template<typename T>
|
inlineprotectedvirtual |
Reimplemented in elastoplastic::core::HookeLaw< T >.
References constitutive::ConstitutiveModelBase< T >::stiffness().
Here is the call graph for this function:
◆ E()
template<typename T>
|
inline |
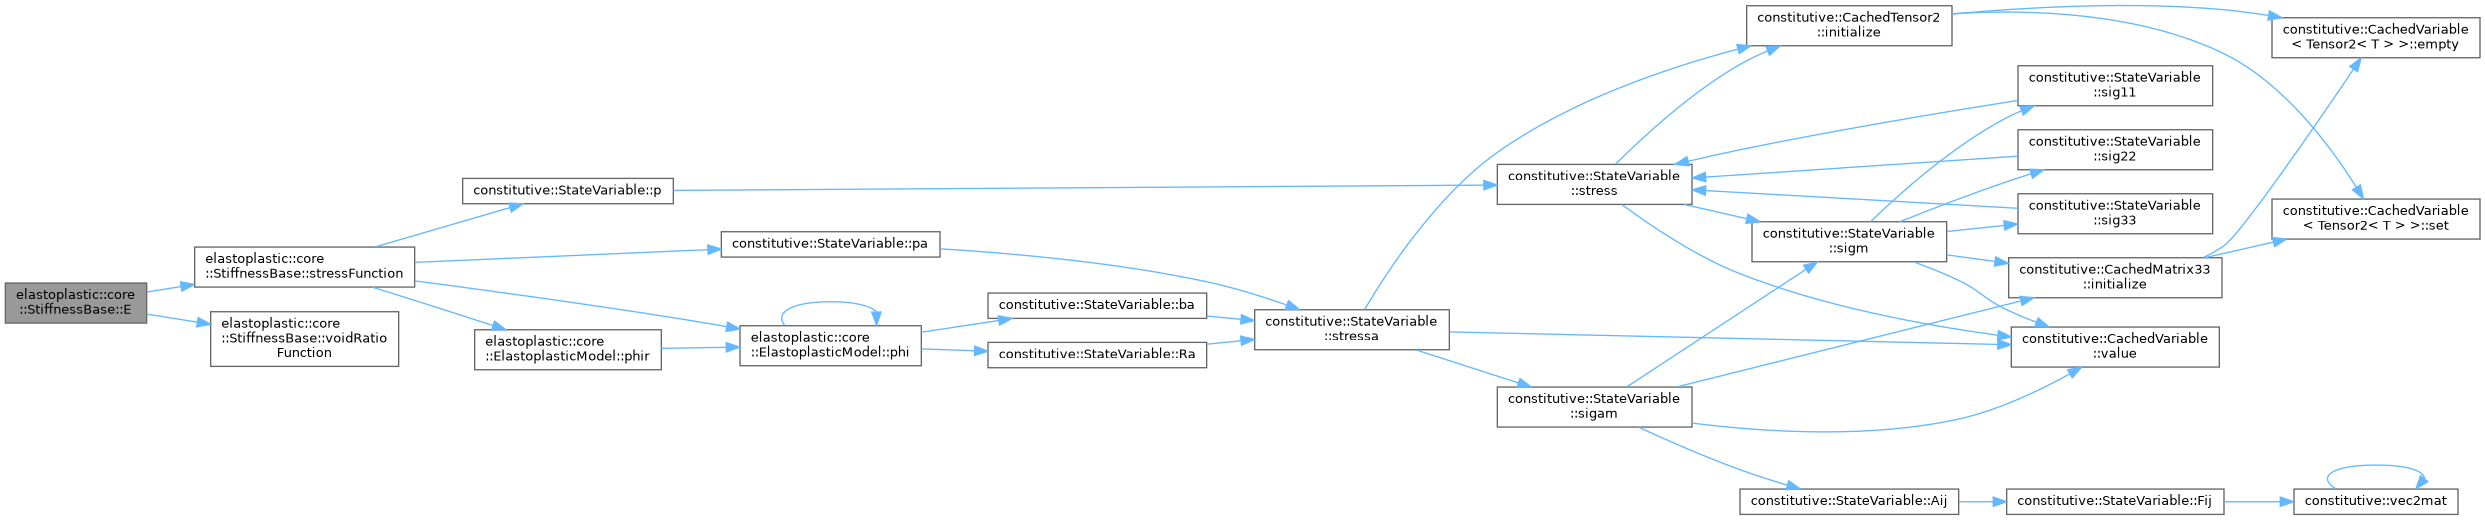
References elastoplastic::core::ElastoplasticModel< T >::material, stressFunction(), and voidRatioFunction().
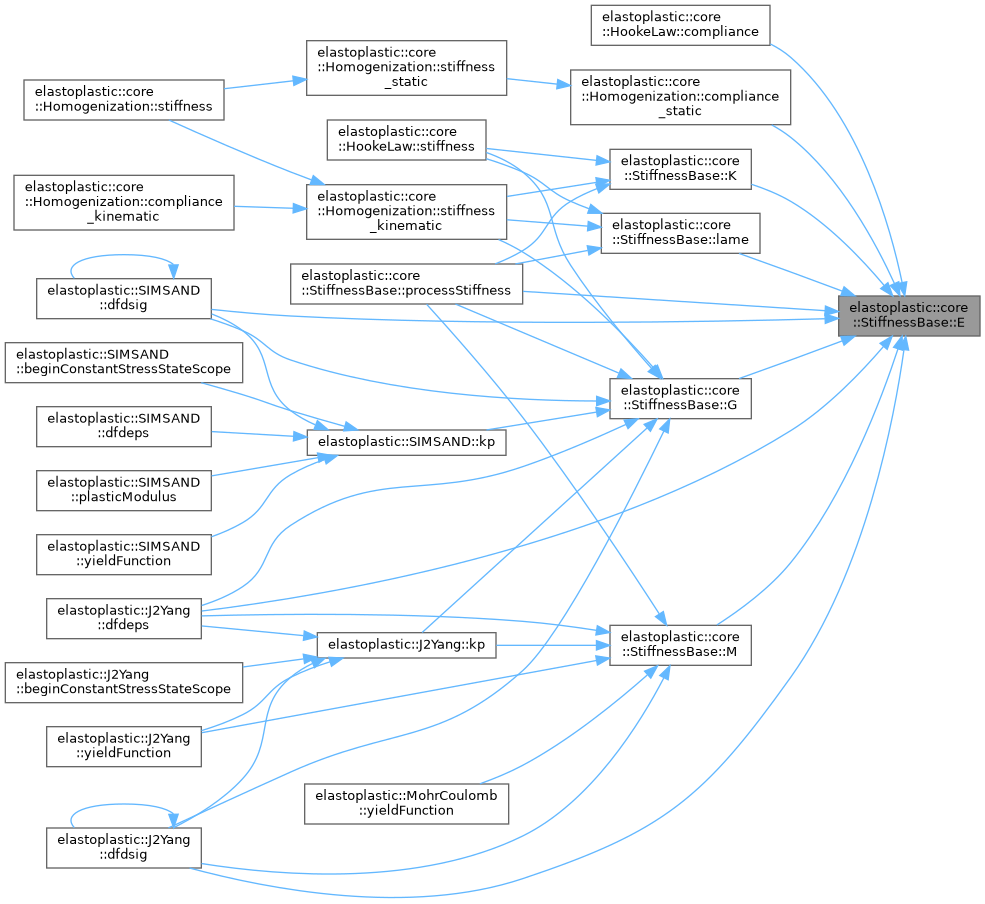
Referenced by elastoplastic::core::HookeLaw< T >::compliance(), elastoplastic::core::Homogenization< T >::compliance_static(), elastoplastic::J2Yang< T >::dfdeps(), elastoplastic::J2Yang< T >::dfdsig(), elastoplastic::SIMSAND< T >::dfdsig(), G(), K(), lame(), M(), and processStiffness().
Here is the call graph for this function:
Here is the caller graph for this function:
◆ G()
template<typename T>
|
inline |
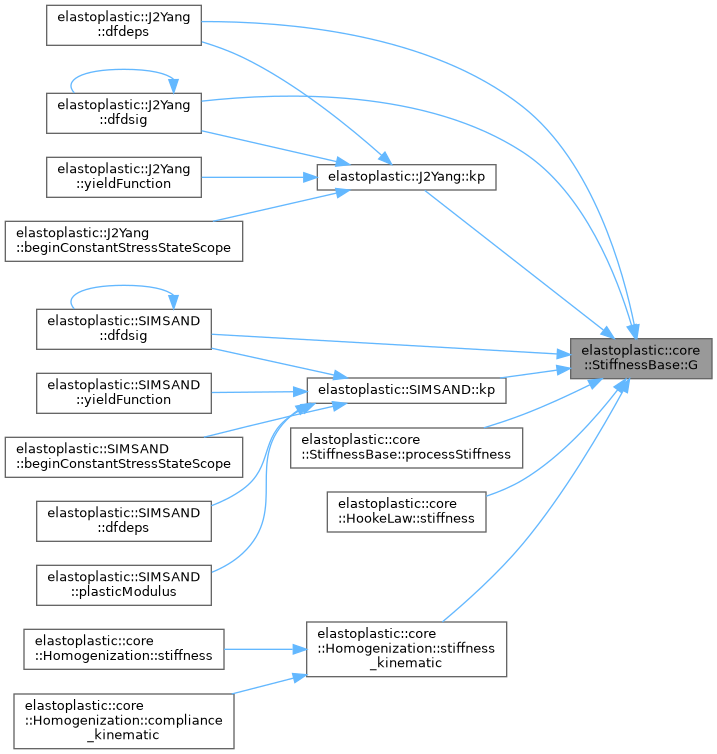
Referenced by elastoplastic::J2Yang< T >::dfdeps(), elastoplastic::J2Yang< T >::dfdsig(), elastoplastic::SIMSAND< T >::dfdsig(), elastoplastic::J2Yang< T >::kp(), elastoplastic::SIMSAND< T >::kp(), processStiffness(), elastoplastic::core::HookeLaw< T >::stiffness(), and elastoplastic::core::Homogenization< T >::stiffness_kinematic().
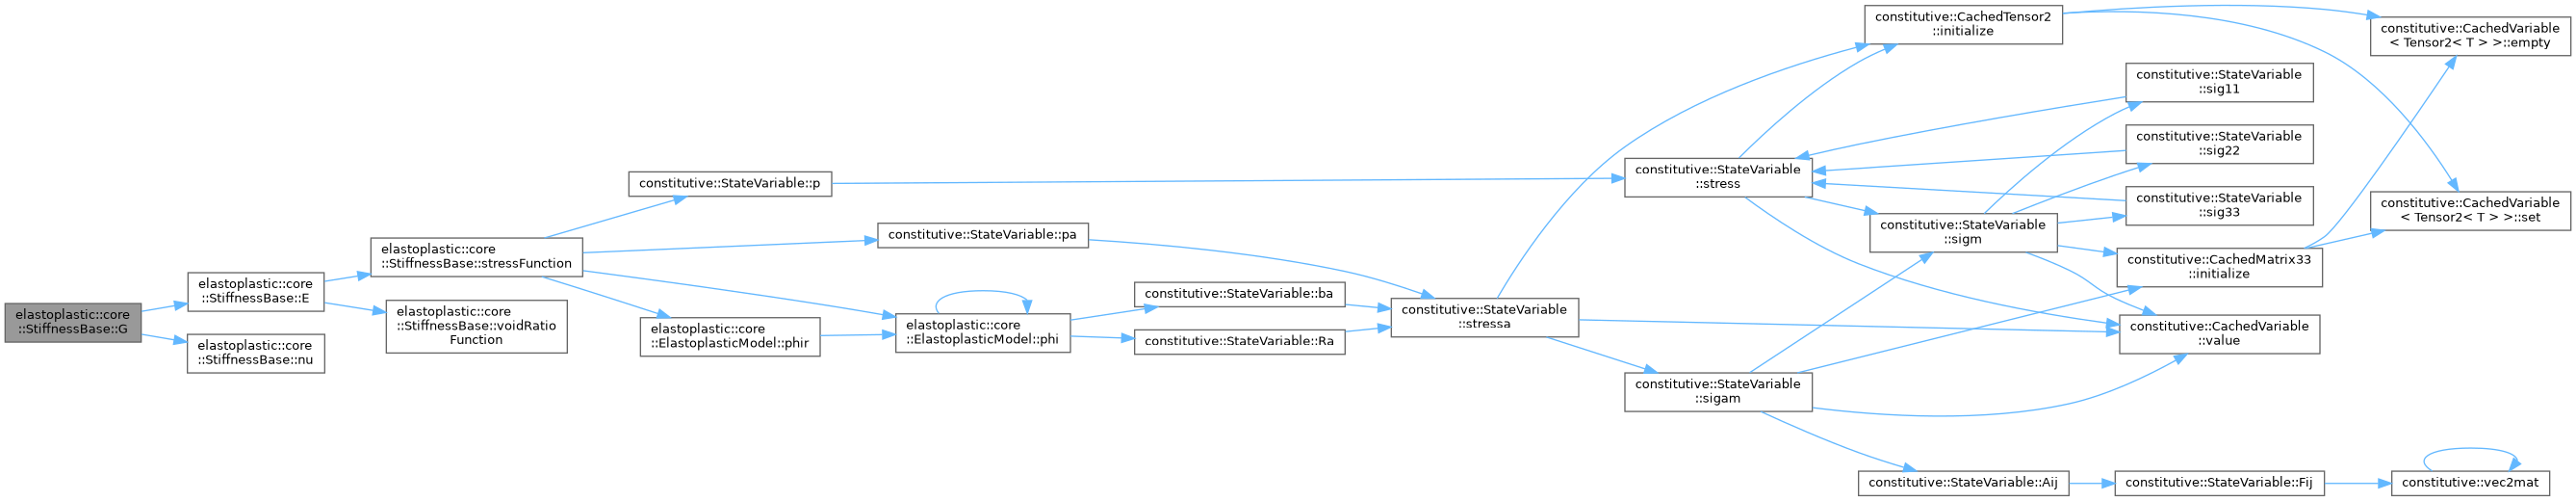
Here is the call graph for this function:
Here is the caller graph for this function:
◆ K()
template<typename T>
|
inline |
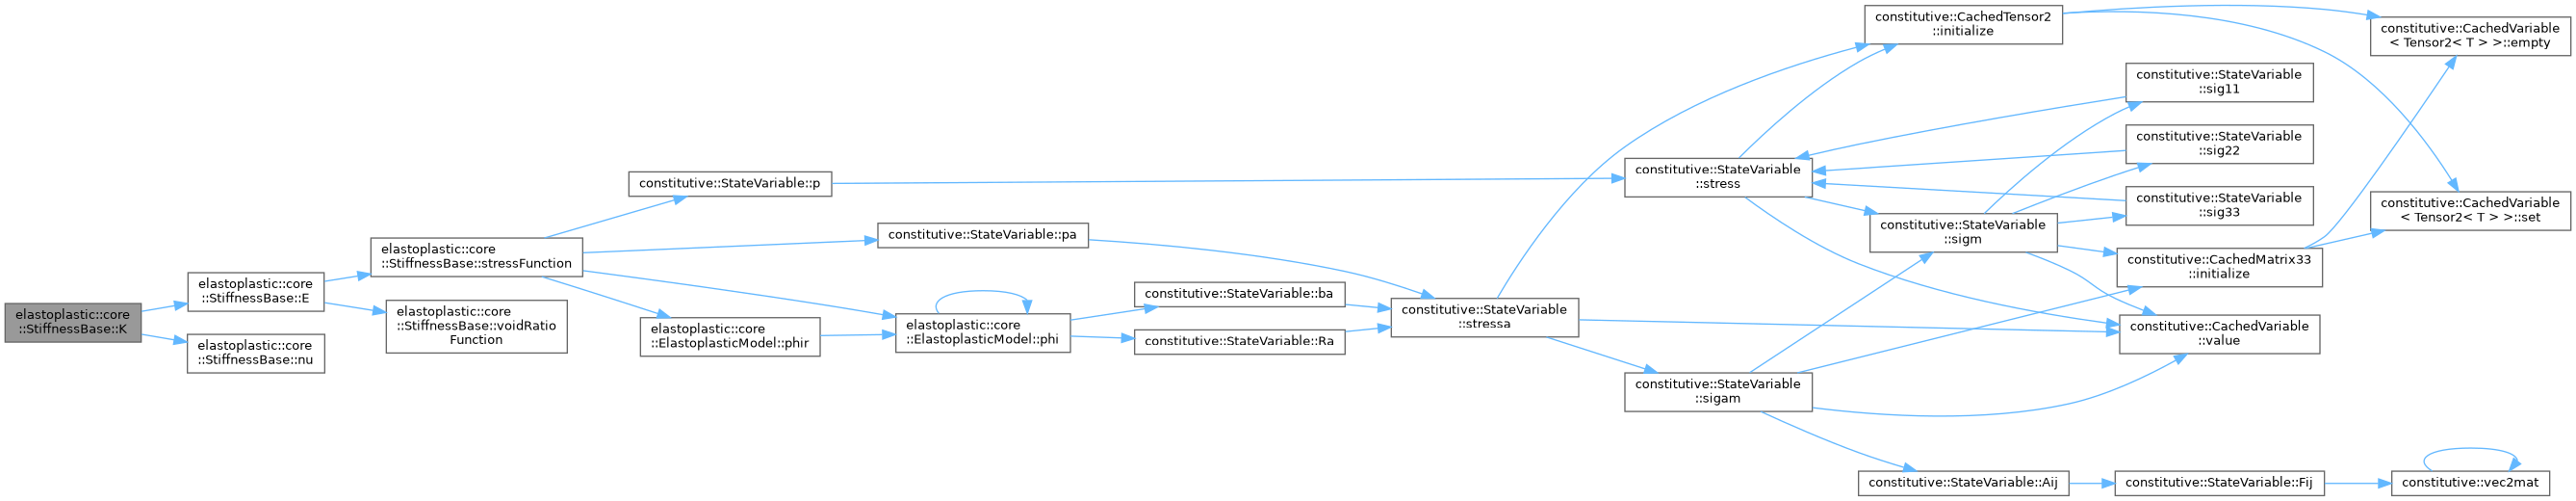
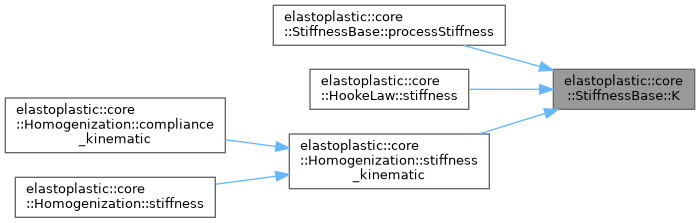
Referenced by processStiffness(), elastoplastic::core::HookeLaw< T >::stiffness(), and elastoplastic::core::Homogenization< T >::stiffness_kinematic().
Here is the call graph for this function:
Here is the caller graph for this function:
◆ lame()
template<typename T>
|
inline |
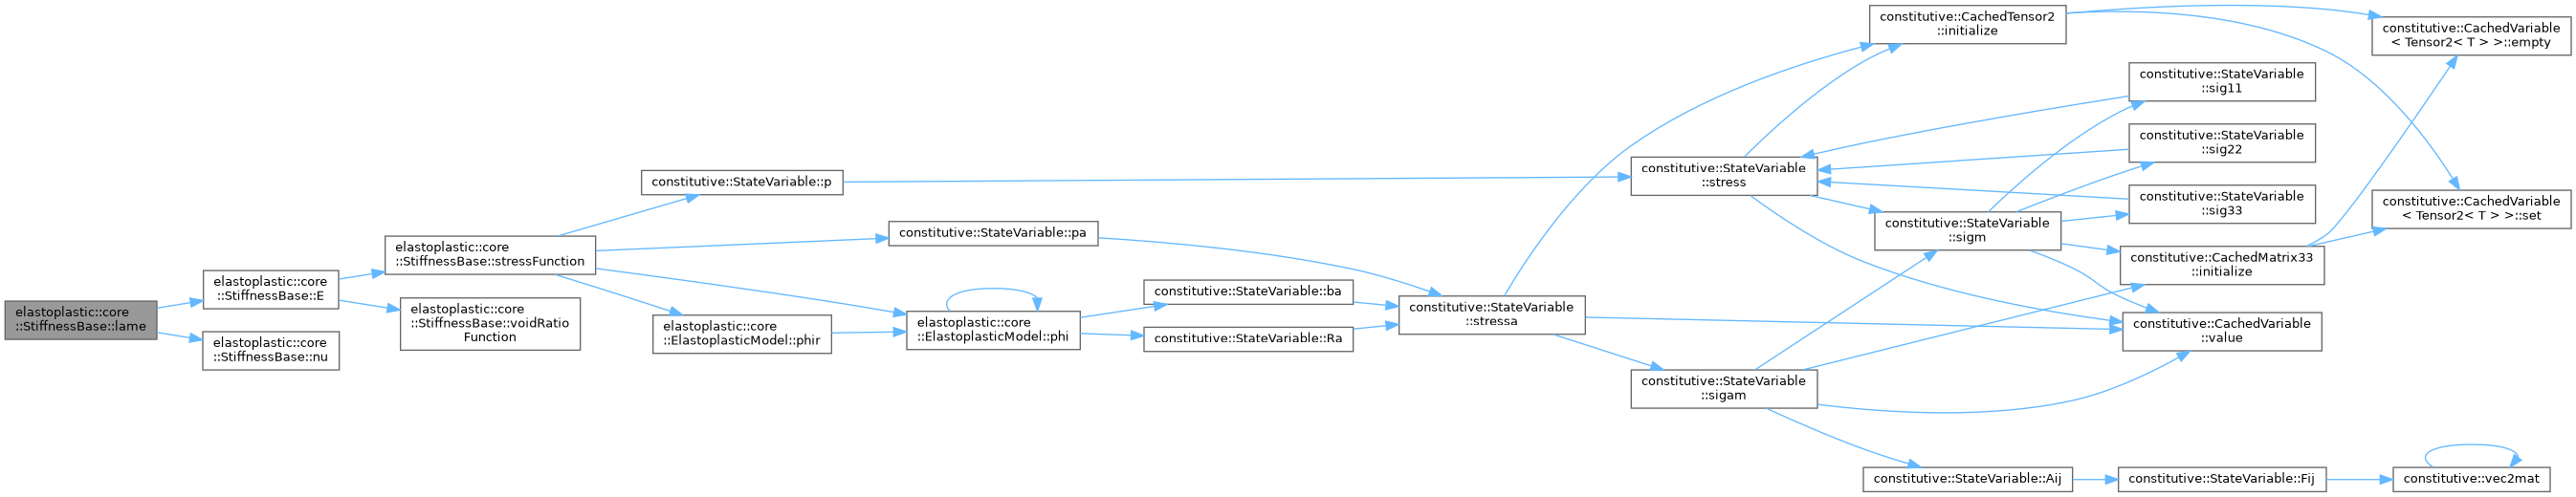
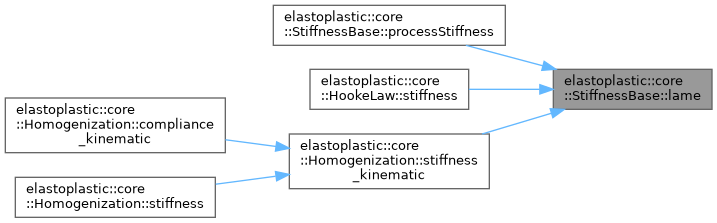
Referenced by processStiffness(), elastoplastic::core::HookeLaw< T >::stiffness(), and elastoplastic::core::Homogenization< T >::stiffness_kinematic().
Here is the call graph for this function:
Here is the caller graph for this function:
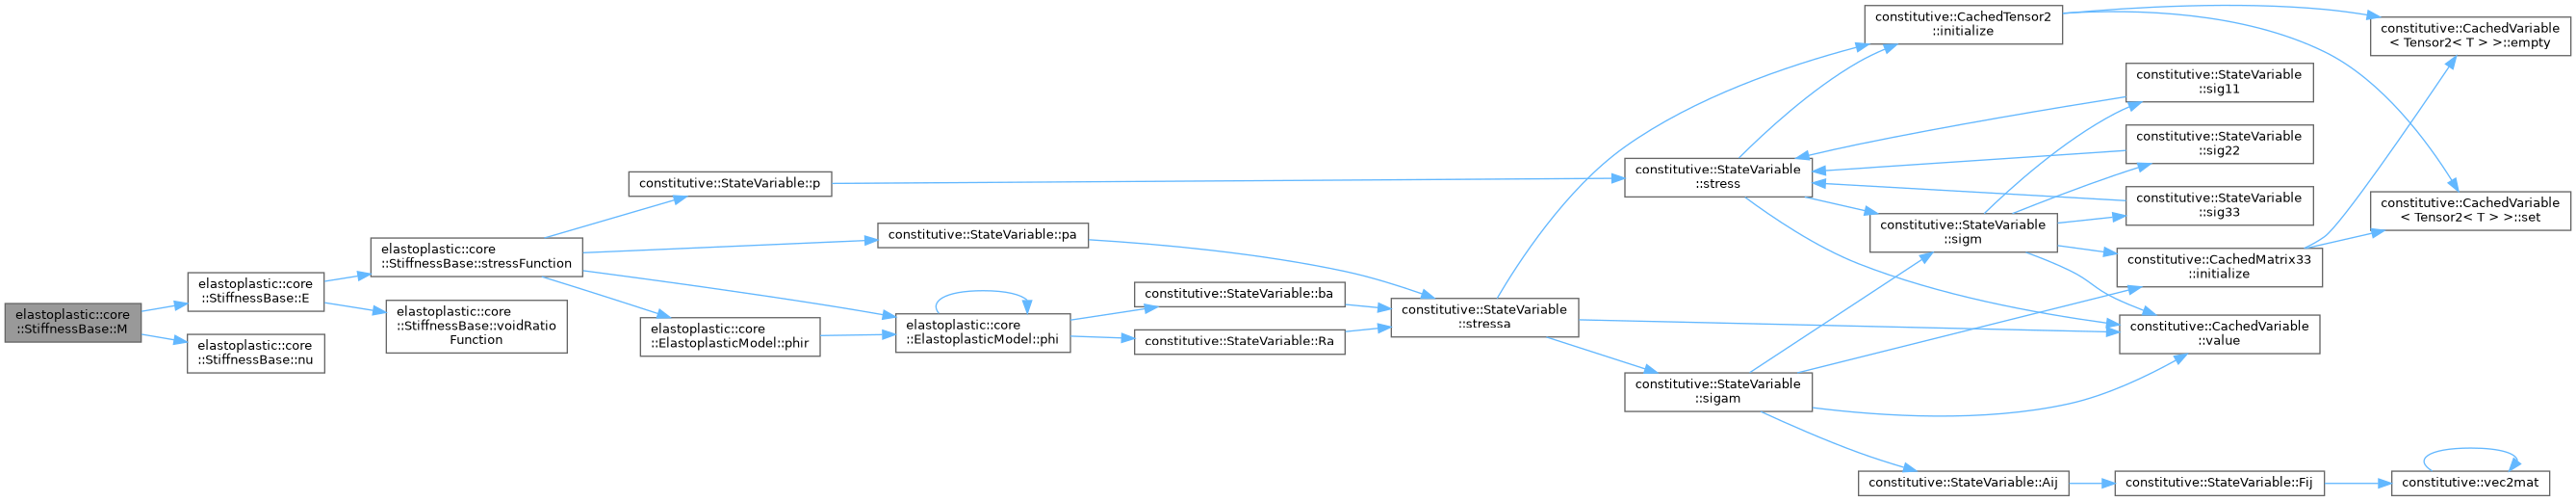
◆ M()
template<typename T>
|
inline |
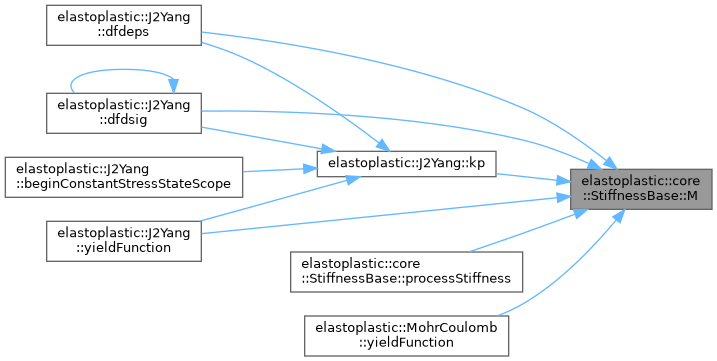
Referenced by elastoplastic::J2Yang< T >::dfdeps(), elastoplastic::J2Yang< T >::dfdsig(), elastoplastic::J2Yang< T >::kp(), processStiffness(), elastoplastic::J2Yang< T >::yieldFunction(), and elastoplastic::MohrCoulomb< T >::yieldFunction().
Here is the call graph for this function:
Here is the caller graph for this function:
◆ nu()
template<typename T>
|
inline |
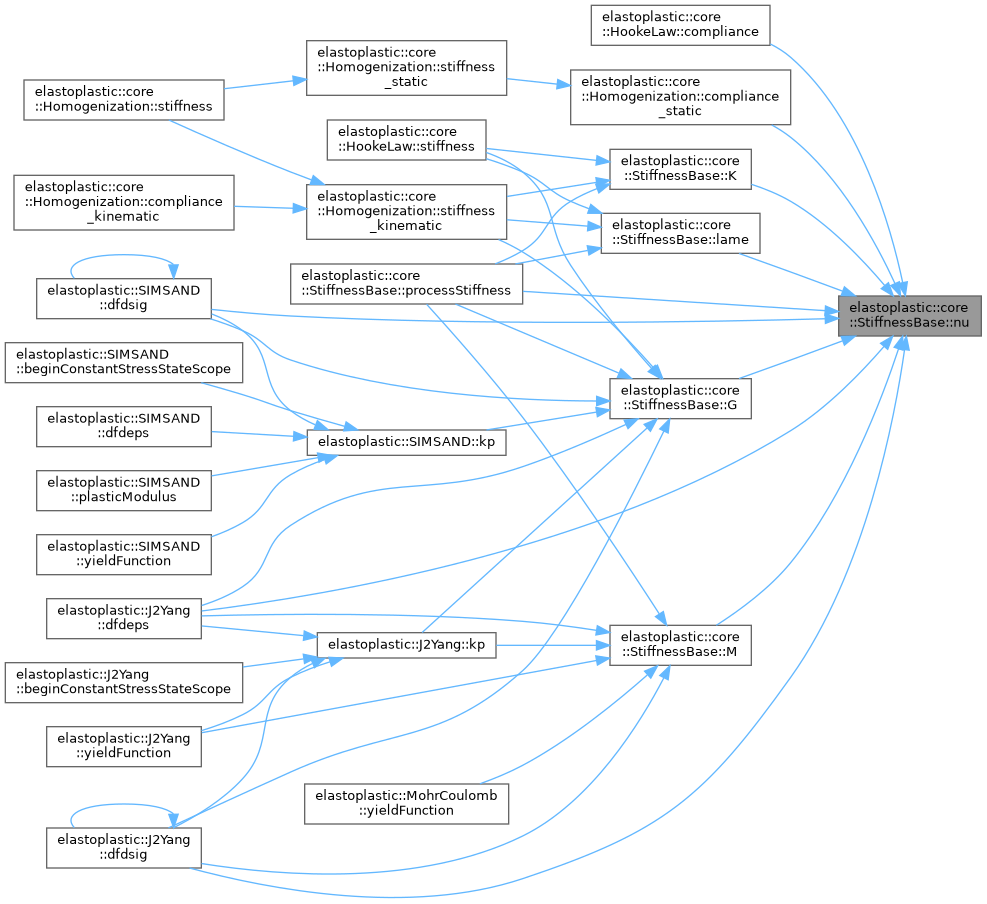
References elastoplastic::core::ElastoplasticModel< T >::material.
Referenced by elastoplastic::core::HookeLaw< T >::compliance(), elastoplastic::core::Homogenization< T >::compliance_static(), elastoplastic::J2Yang< T >::dfdeps(), elastoplastic::J2Yang< T >::dfdsig(), elastoplastic::SIMSAND< T >::dfdsig(), G(), K(), lame(), M(), and processStiffness().
Here is the caller graph for this function:
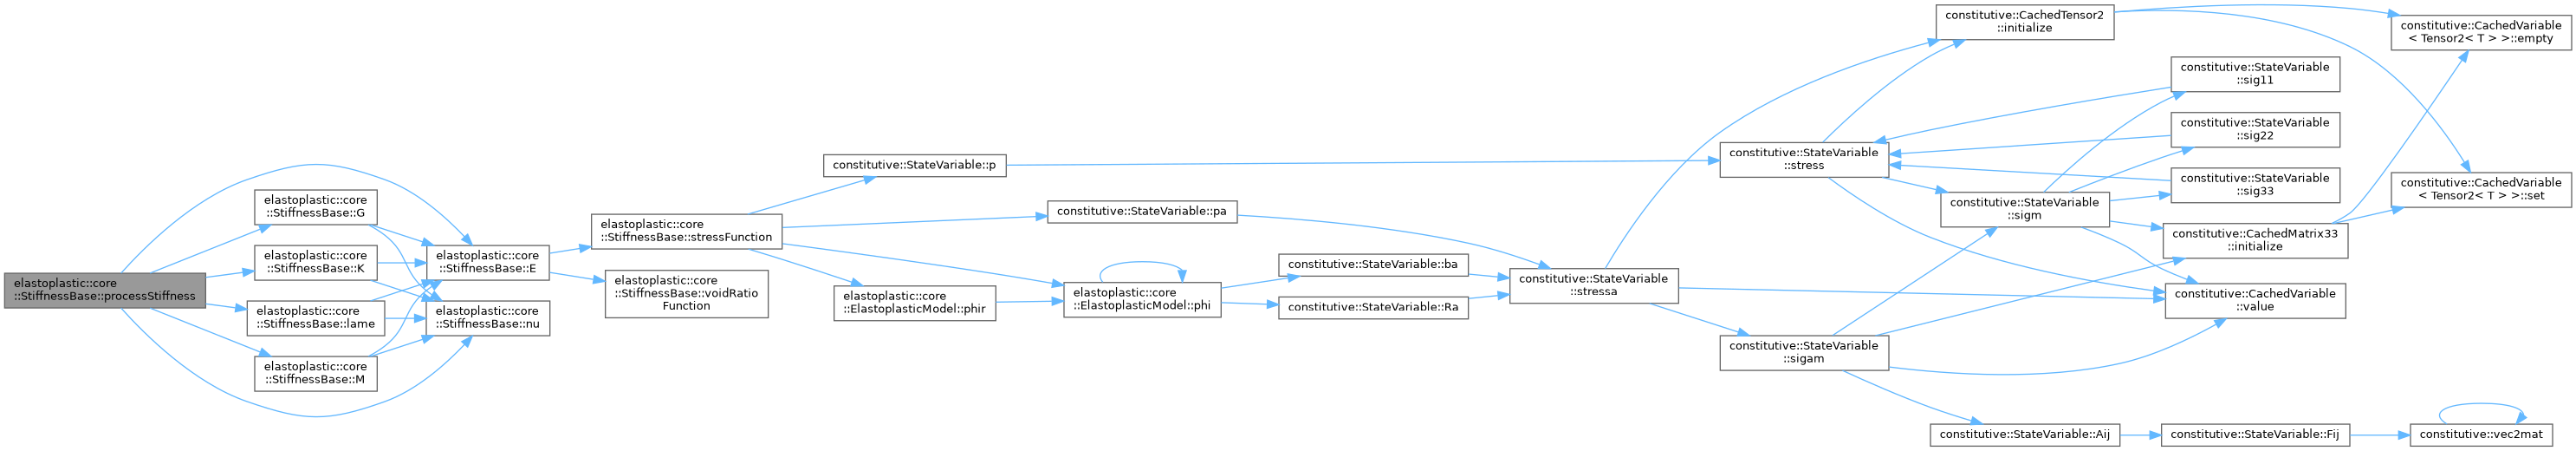
◆ processStiffness()
template<typename T>
|
inline |
◆ stressFunction()
template<typename T>
|
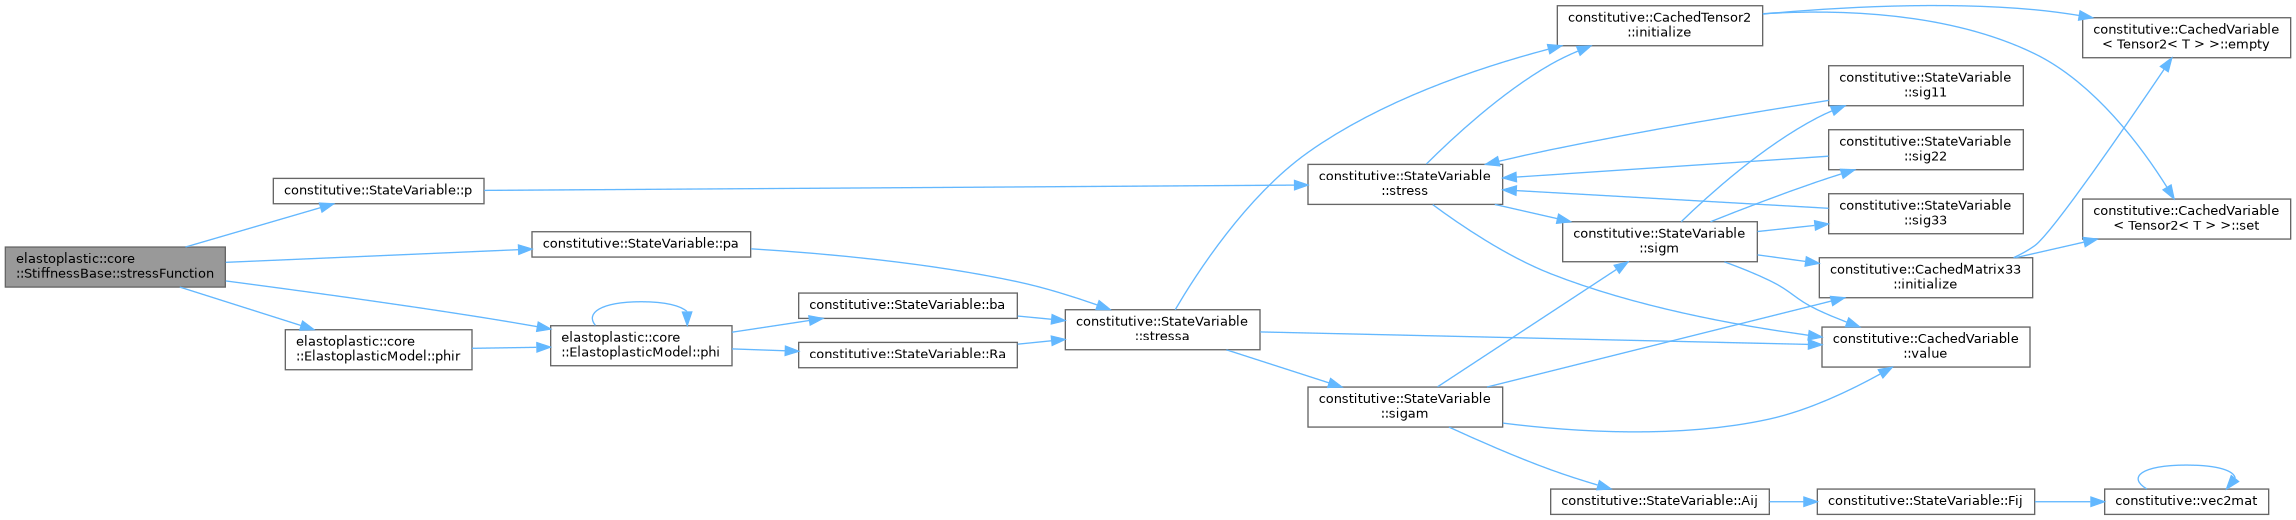
inlineprotected |
References elastoplastic::core::ElastoplasticModel< T >::material, constitutive::ConstitutiveModelBase< T >::options, constitutive::StateVariable< T >::p(), constitutive::StateVariable< T >::pa(), elastoplastic::core::ElastoplasticModel< T >::phi(), and elastoplastic::core::ElastoplasticModel< T >::phir().
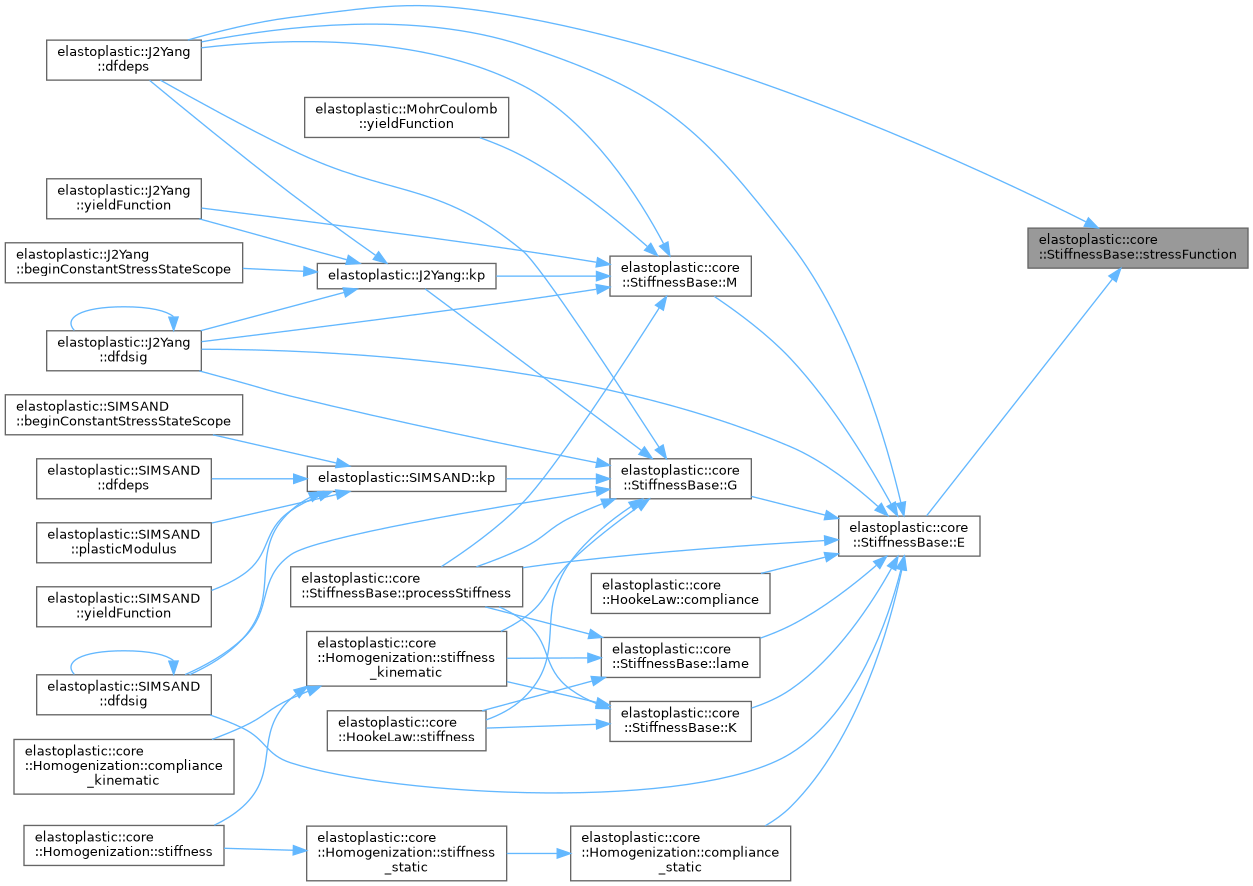
Referenced by elastoplastic::J2Yang< T >::dfdeps(), and E().
Here is the call graph for this function:
Here is the caller graph for this function:
◆ voidRatioFunction()
template<typename T>
|
inlineprotected |
References constitutive::StateVariable< T >::e, elastoplastic::core::ElastoplasticModel< T >::material, and constitutive::ConstitutiveModelBase< T >::options.
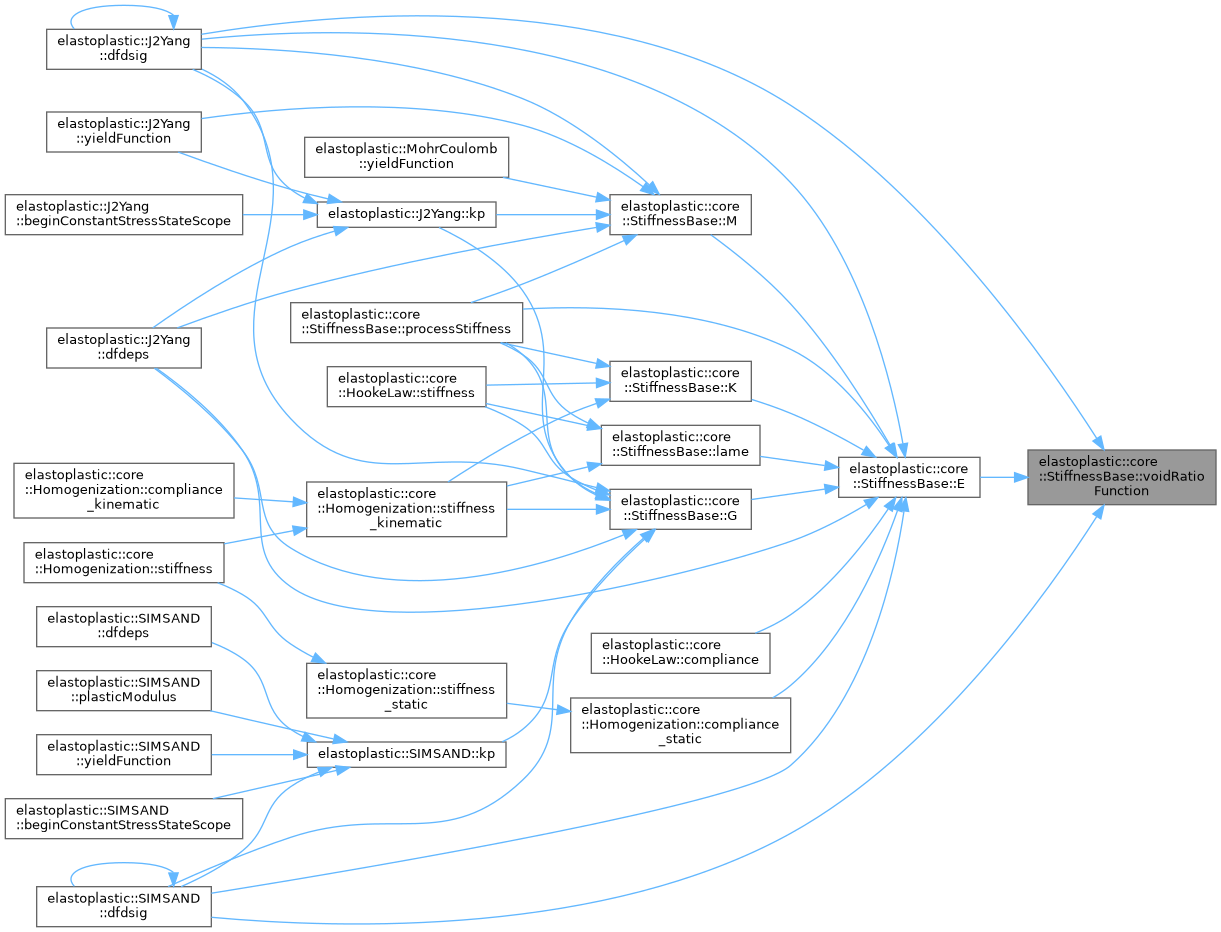
Referenced by elastoplastic::J2Yang< T >::dfdsig(), elastoplastic::SIMSAND< T >::dfdsig(), and E().
Here is the caller graph for this function:
The documentation for this struct was generated from the following file:
- include/elastoplastic/core/stiffness.hpp